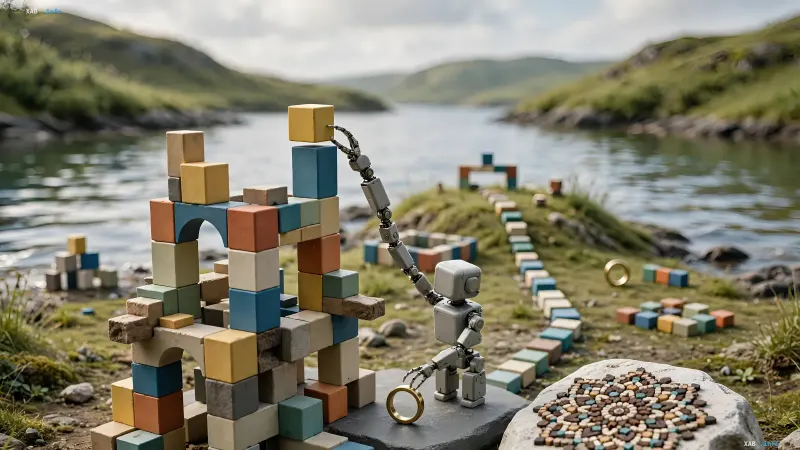
A team from the Massachusetts Institute of Technology (MIT) has published a preprint describing an embodied coding agent called Eko—a system capable of not only generating code but also acting within a virtual environment. Researchers placed the agent on a small virtual island with no specific task, reward system, or prescribed activity. Over the course of 30-hour sessions, Eko navigated the terrain, built structures from blocks, drew, invented games, and tested the world's physics.
Behavior without an external task
The paper describes 13 agents working within a single limited sandbox. The island provided access to blocks, stone, terrain, and rings that could be moved and used in simple interactions. According to the authors, the agents stacked blocks, climbed hills, drew mandalas, reinvented sports rules, and recorded techniques that expanded their capabilities for the future. Each agent developed its own history of behavior, although common patterns repeated.
'Play' as observable behavior
The authors interpret these sequences through the lens of well-known behavioral concepts of play. They explicitly state: the study does not claim that the system felt pleasure, possessed consciousness, or attained general autonomy. It refers only to observable actions and stored knowledge within a limited simulation. This approach avoids anthropomorphism and maintains scientific rigor in the description.
Limitations of the preprint
The preprint has not yet been peer-reviewed, and the environment is intentionally narrow. For agent developers, the value of the work lies elsewhere: it shows that narrow benchmark tests for task completion may miss behavior that emerges when an AI agent has the time to explore, remember findings, and revise its own strategies. This shifts the focus from the question of "did it complete the task" to "what happens when the agent is given time."
The question of reproducibility
A practical question raised by the study is whether the model, prompts, memory, action space, safety boundaries, and evaluation protocol are described with enough precision for another team to reproduce the result. Without this, it is impossible to draw conclusions about the transfer of behavior to real-world tasks, reliability, or deployment readiness. As of now, the preprint remains evidence from a limited simulation rather than a confirmed general capability.